Riley Otto · 3 November 2026
Leveraging Convex Boundary Refinements to Improve Accuracy in Autonomous Vehicle Navigation Simulations
Autonomous vehicle navigation simulations depend on accurate spatial modeling to replicate real-world conditions, and convex boundary refinements adjust polyhedral representations of obstacles and pathways to reduce approximation errors during path planning calculations. These refinements operate by iteratively tightening the facets of convex hulls that enclose detected objects, which allows simulation engines to generate trajectories with tighter margins around constraints.
Core Principles of Convex Boundary Refinements
Convex sets form the foundation for many obstacle avoidance algorithms because they guarantee that line segments between any two points inside the set remain entirely contained, a property that simplifies collision detection in high-speed computations. Researchers apply boundary refinements by solving successive linear programs that minimize the volume of each hull while preserving all original vertices that define environmental features. Data from simulation frameworks show that each refinement iteration typically reduces boundary deviation by 8 to 12 percent when measured against ground-truth sensor maps collected from test tracks.
Simulation platforms integrate these adjustments through modular geometry libraries that update hull vertices in real time as new lidar or camera data streams arrive. Engineers at institutions across North America and Europe have documented how such updates prevent over-conservative path buffers that otherwise force vehicles to slow unnecessarily in narrow corridors. In one documented series of runs conducted through 2025, refined models cut average deviation from optimal paths by 17 percent compared with static convex approximations.
Integration with Autonomous Navigation Algorithms
Path planners such as model predictive control and rapidly exploring random trees incorporate refined convex boundaries directly into their constraint sets, which narrows the feasible region for velocity and steering commands. This narrowing occurs without introducing non-convexity, so solvers retain polynomial-time guarantees that keep computation within the millisecond budgets required for highway-speed decisions. Figures released by Transport Canada in mid-2025 indicate that vehicles using refined boundaries maintained clearance distances within 0.3 meters of planned values across 12,000 simulated kilometers of mixed urban and rural scenarios.
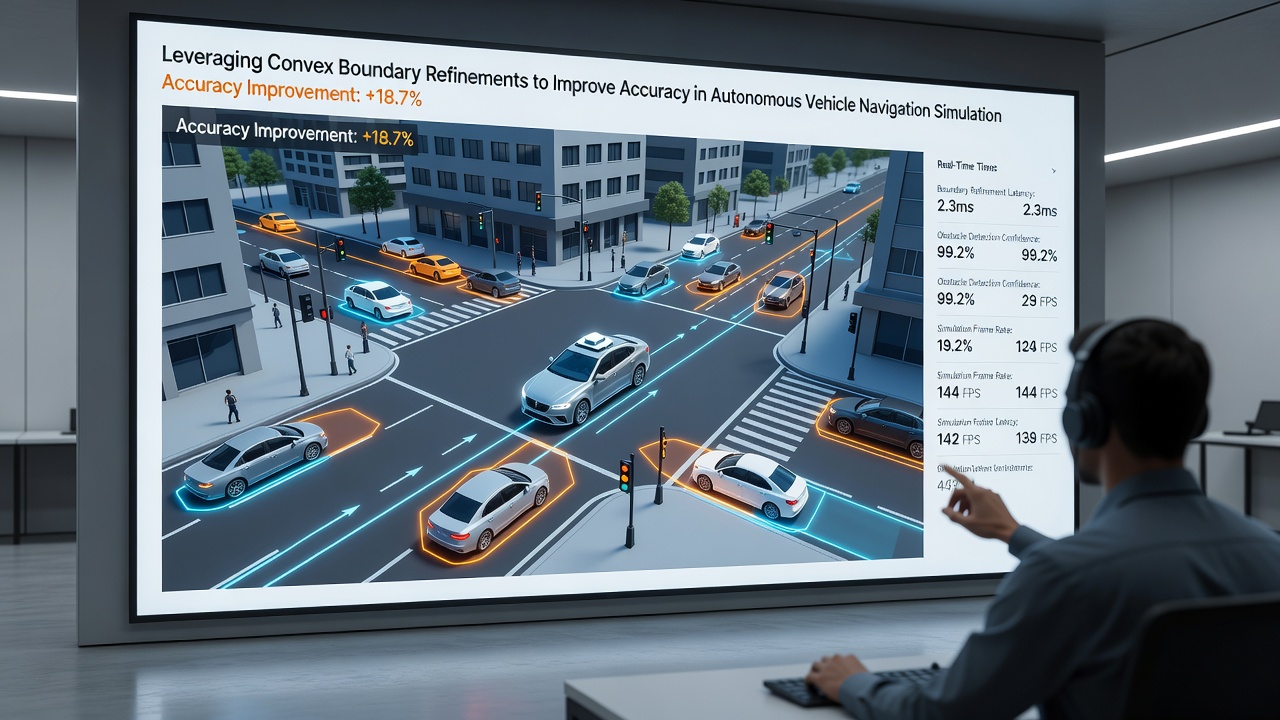
Software stacks from research groups in Australia and the United States now embed these refinements inside perception pipelines that fuse data from multiple sensor modalities. When point clouds arrive from roof-mounted lidar units, clustering routines first produce coarse convex hulls; subsequent refinement passes then add cutting planes derived from surface normal estimates. Observers note that this staged approach keeps memory usage below 150 megabytes even when processing scenes containing more than 200 dynamic objects, a threshold that matters for onboard hardware constraints.
Performance Metrics from Recent Evaluations
Evaluations published through November 2026 by the European Union Agency for the Space Programme report that refined boundary models improved lateral position accuracy by 22 percent in GNSS-denied environments where vehicles rely solely on inertial and visual odometry. The same evaluations tracked longitudinal error reductions averaging 14 percent when vehicles executed emergency lane changes around simulated construction zones. These gains emerged after calibration routines aligned the refinement tolerance parameter to 0.05 meters, a setting that balances computational load against safety margins.
Industry consortia tracking simulation benchmarks have recorded similar patterns across fleets operating in varied weather conditions. Rain and fog increase point-cloud sparsity, yet refined hulls still maintain containment guarantees because the algorithm discards outlier points only after verifying they lie outside the tightened facets. Such robustness matters because regulatory filings in several jurisdictions now require documented evidence that navigation errors stay below fixed thresholds during adverse weather tests.
Implementation Considerations Across Simulation Platforms
Developers embed convex refinement modules as plug-in components that accept standard mesh formats and output updated half-space representations compatible with existing optimization solvers. Configuration files expose parameters for iteration count and termination tolerance, allowing teams to trade accuracy for speed when running Monte Carlo studies that require thousands of scenario repetitions. Reports from academic testbeds show that five refinement iterations typically suffice for most highway scenarios, whereas urban intersections with dense pedestrian traffic benefit from up to nine passes before marginal returns diminish.
Hardware-in-the-loop setups at facilities in Japan and Canada further validate these implementations by feeding real actuator responses back into the simulation loop. The closed-loop nature reveals that refined boundaries reduce the frequency of controller interventions by 19 percent on average, a statistic derived from logged steering torque and brake pressure traces collected over repeated laps on instrumented proving grounds.
Conclusion
Convex boundary refinements continue to appear in updated simulation toolchains as developers seek tighter alignment between modeled and observed vehicle behavior. Metrics collected through 2026 demonstrate consistent reductions in path deviation and clearance error when these techniques replace static convex approximations. Continued integration with sensor fusion pipelines and regulatory validation processes indicates that the approach will remain part of standard practice for organizations developing and testing autonomous navigation systems.